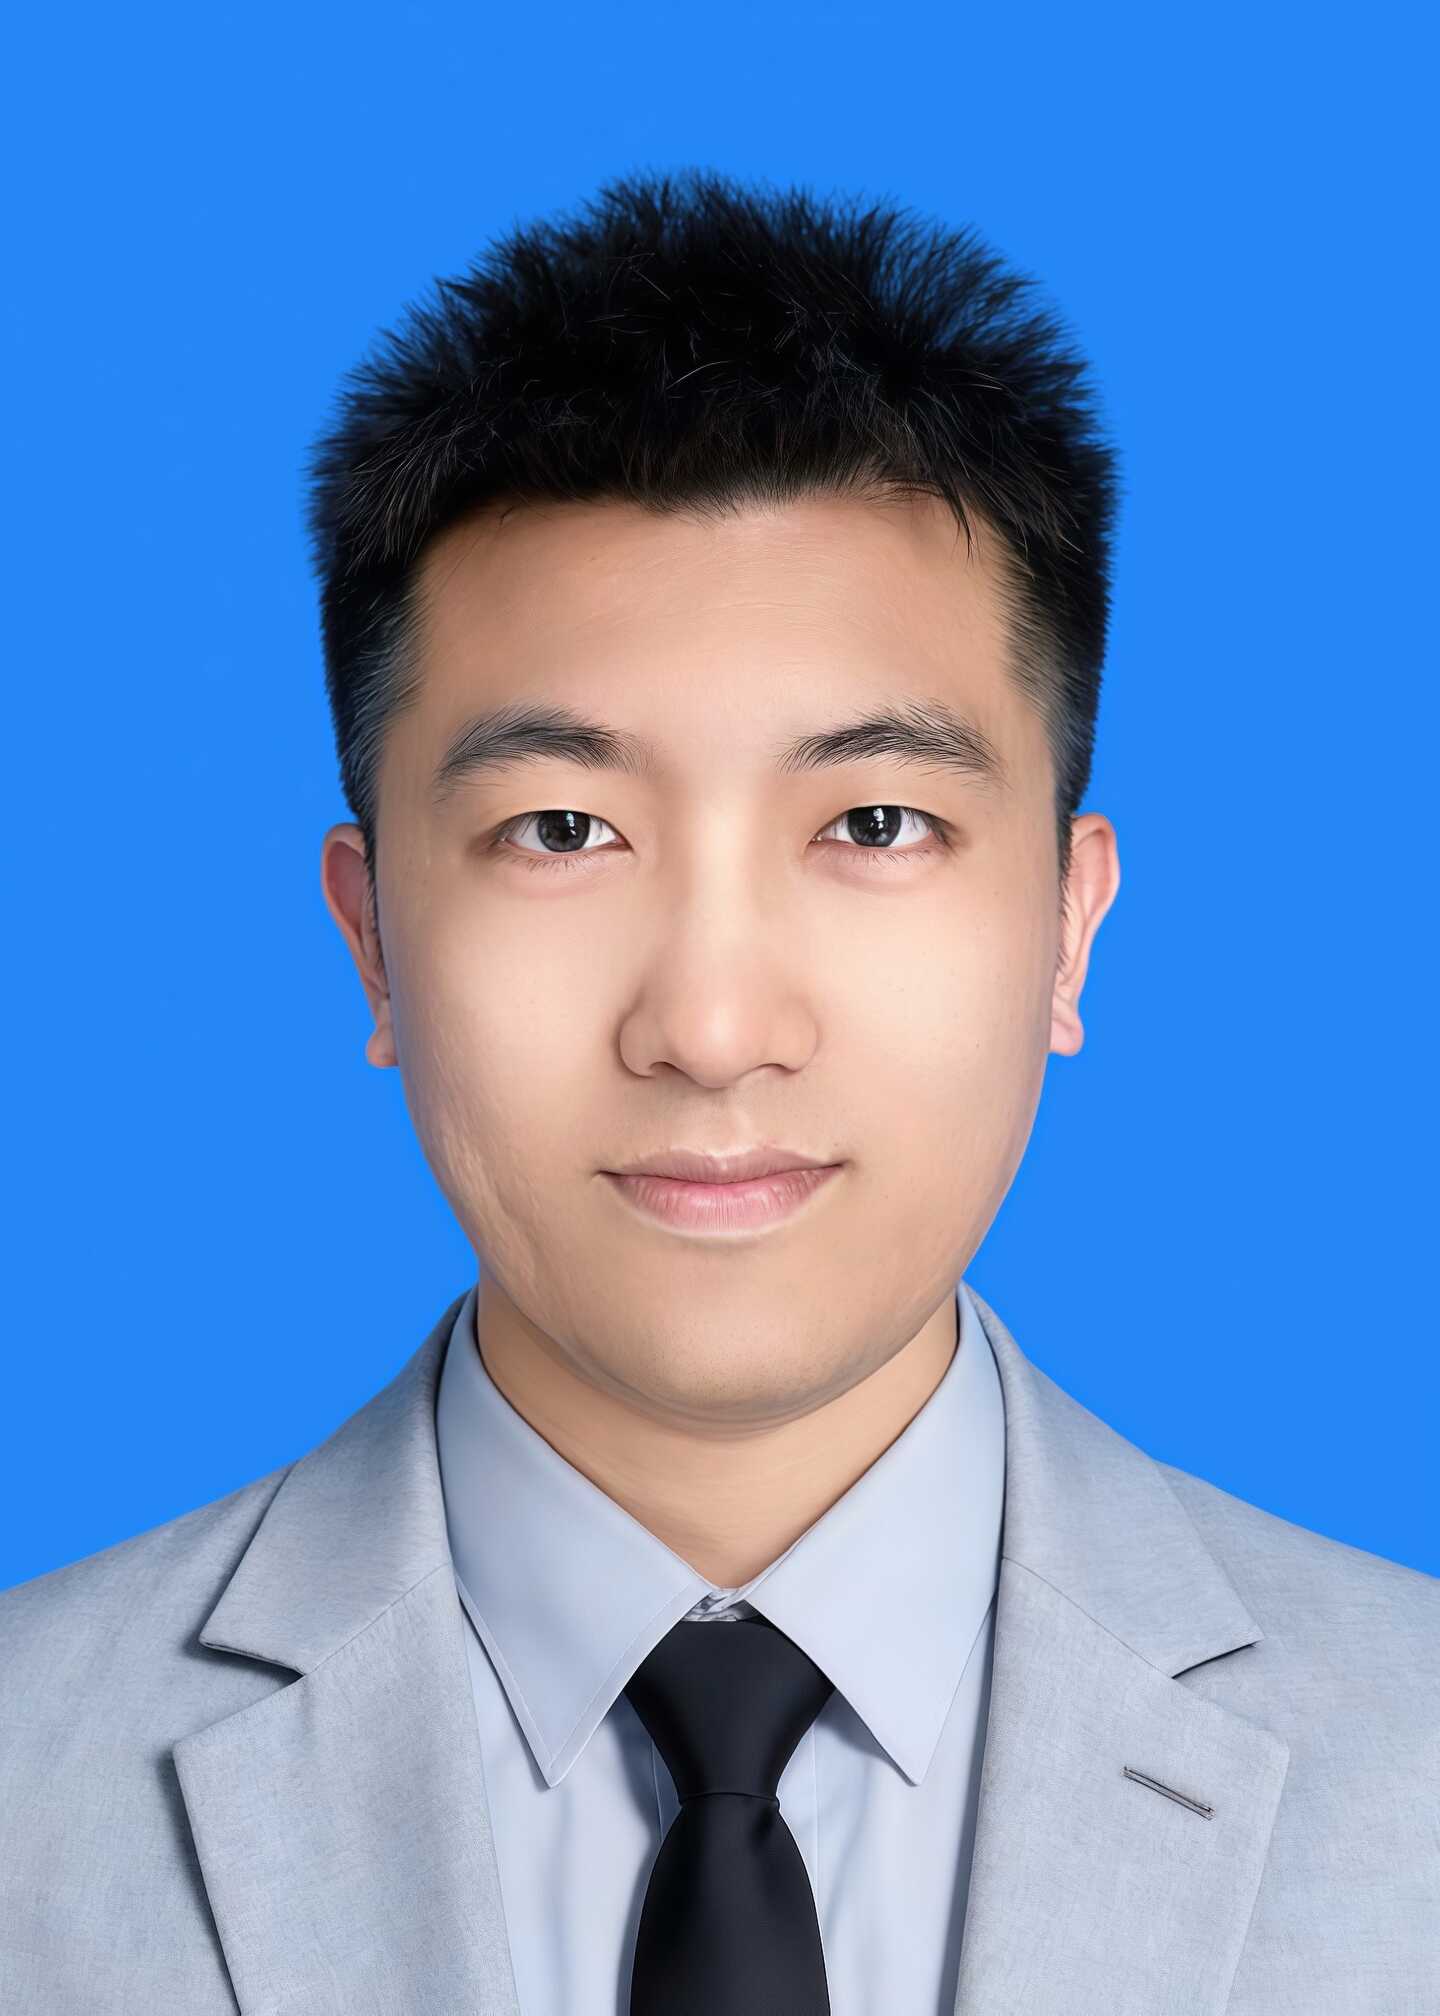
个人简介
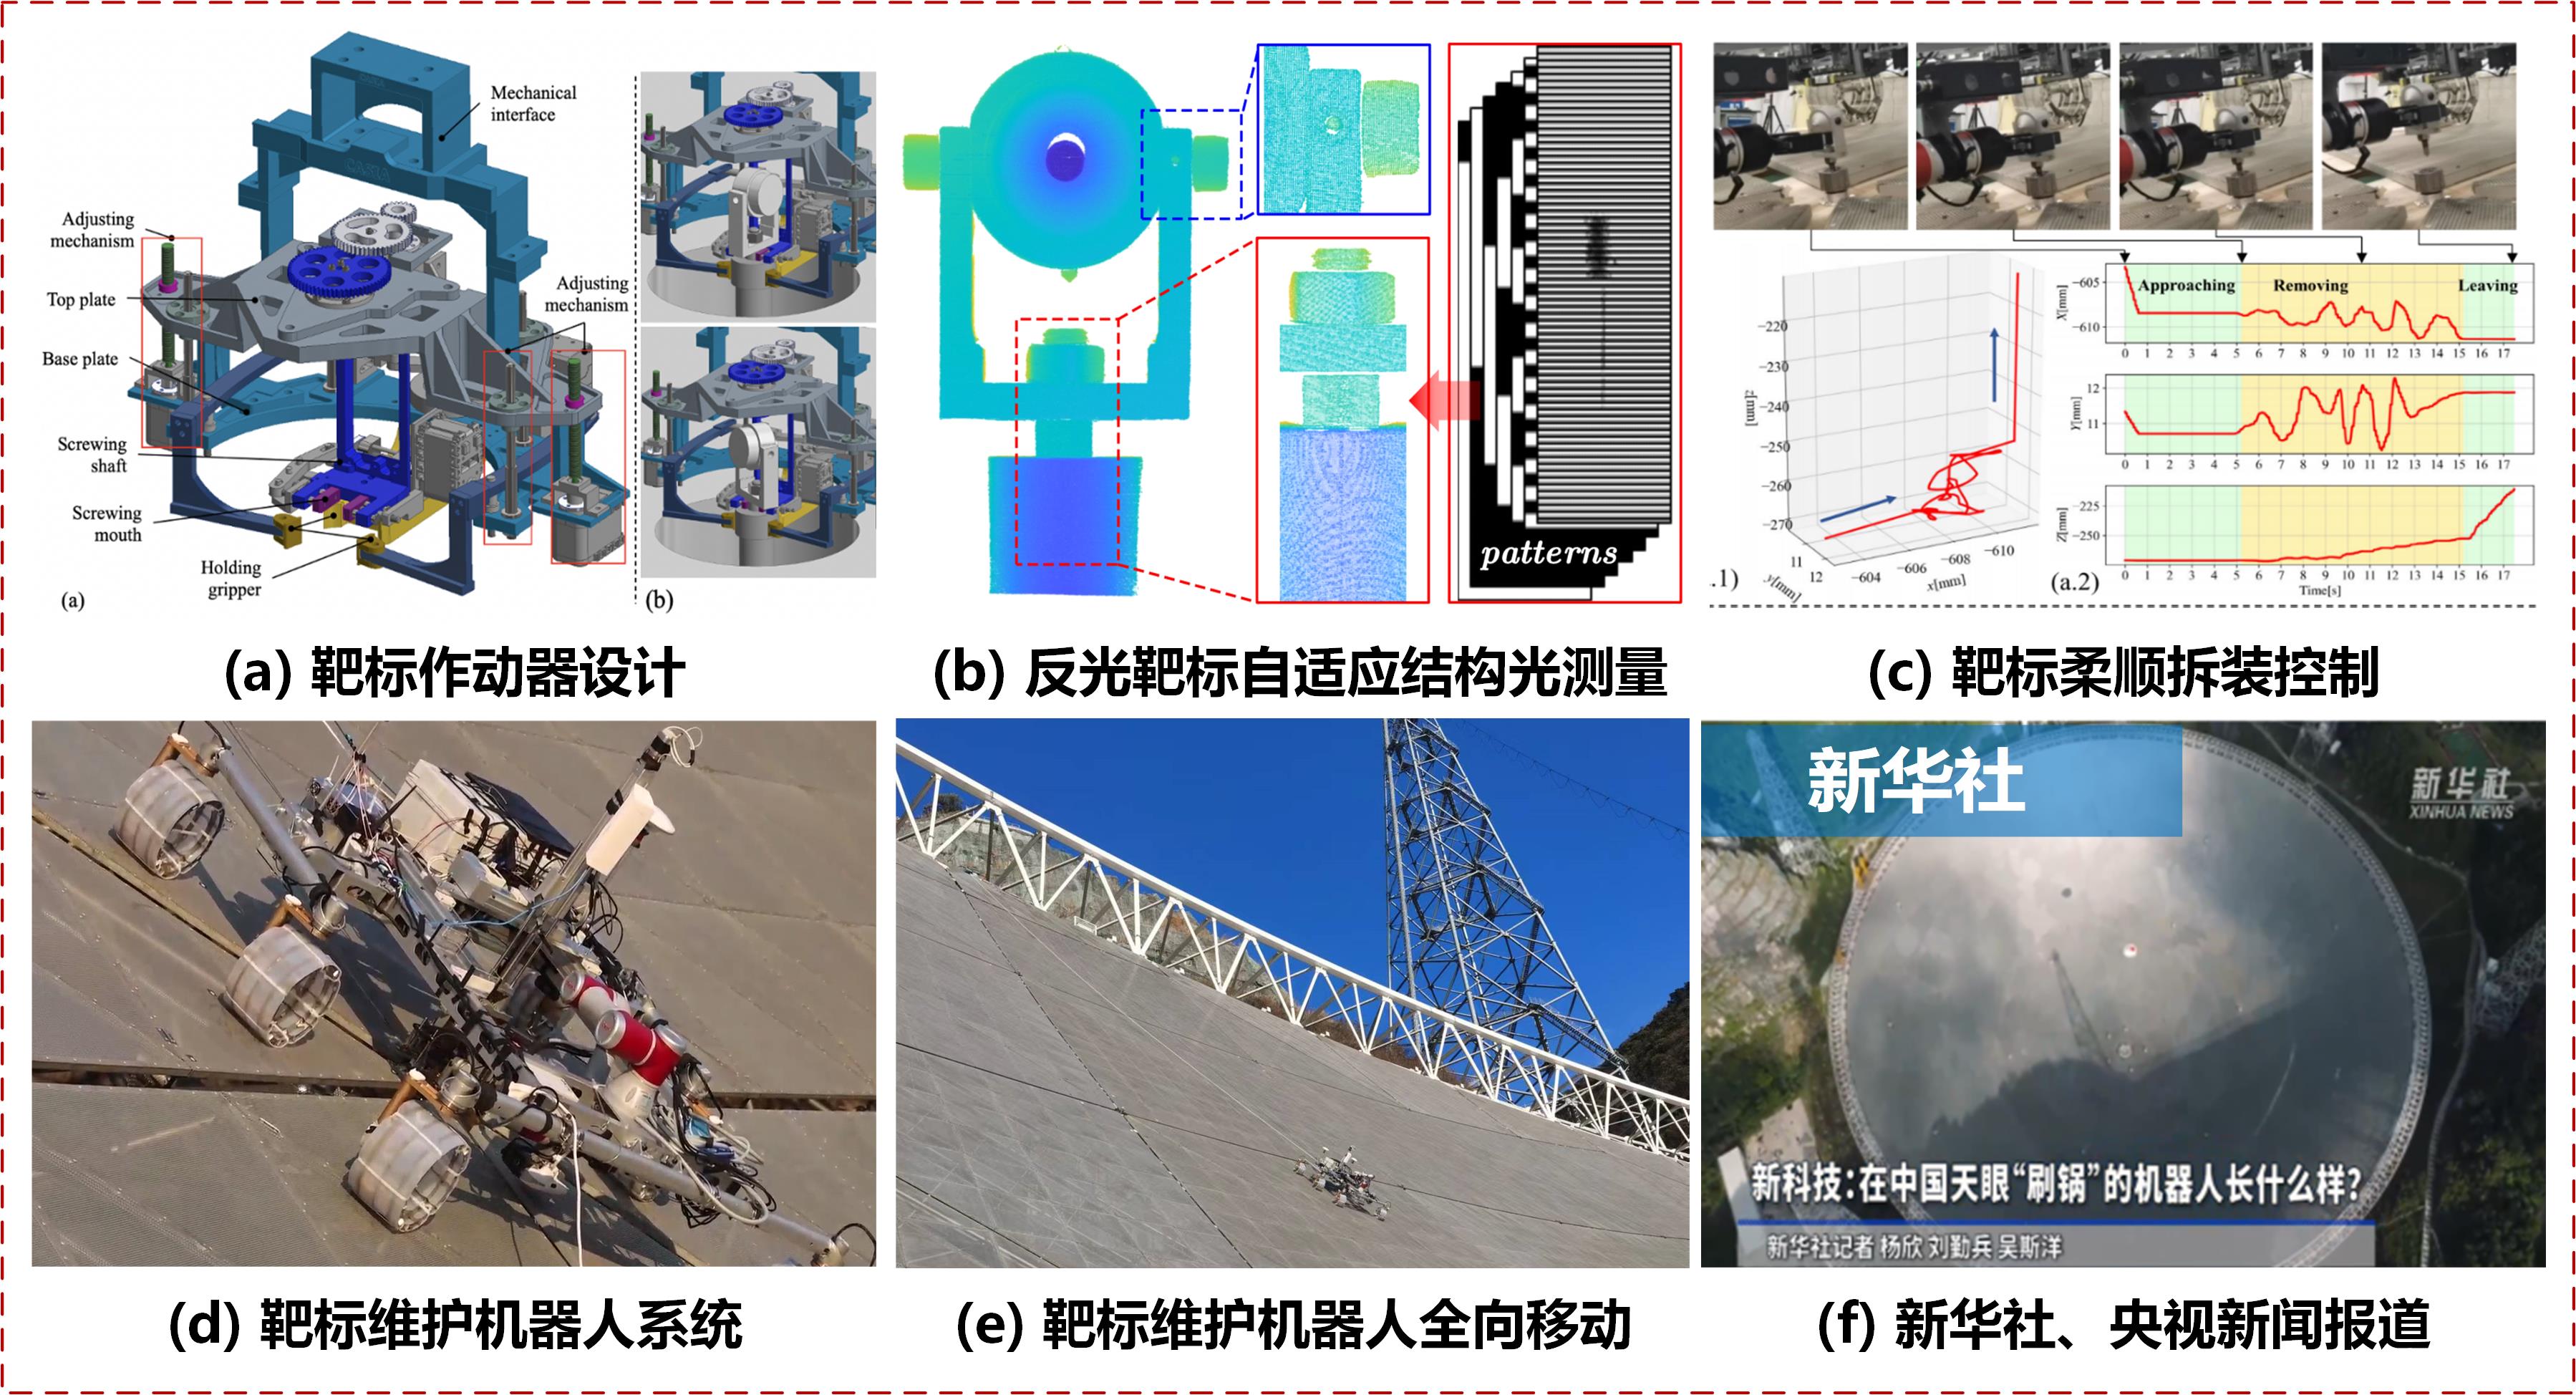
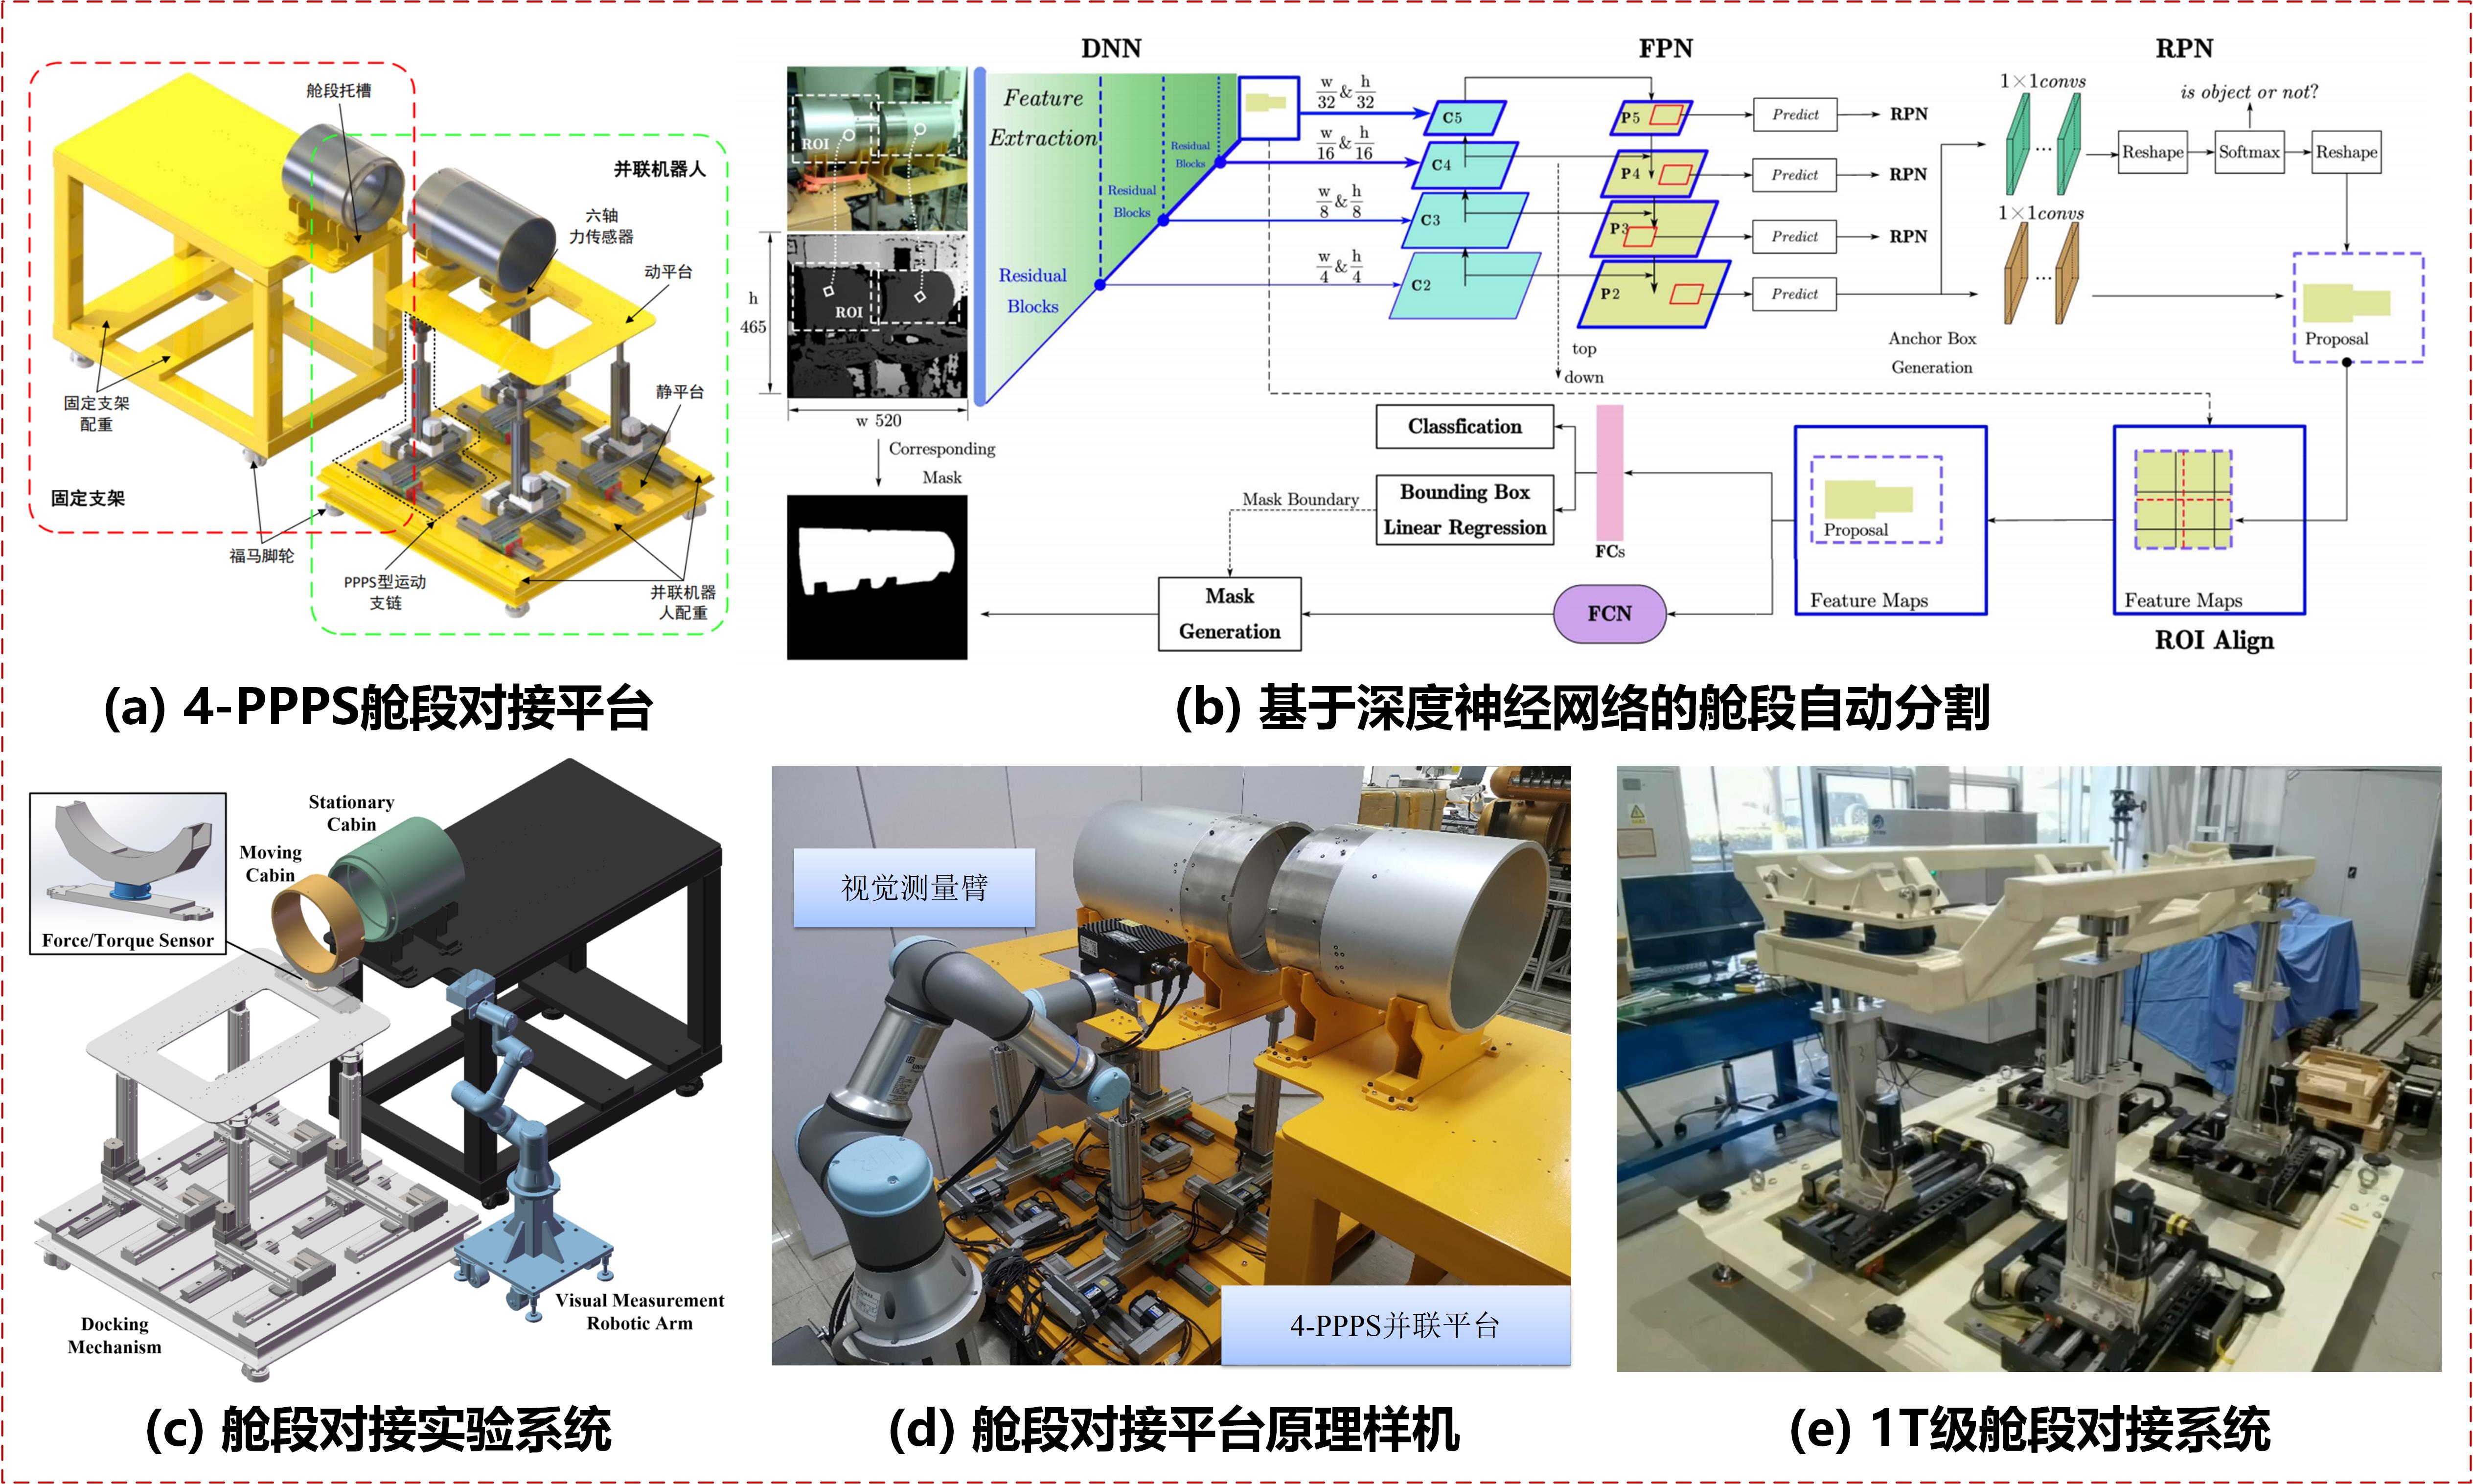
马云开,中国科学院自动化研究所副研究员,长期从事机器人三维感知与精密自主作业研究。面向“制造强国”战略需求,提出了多场景高精度感知与智能操作方法,解决了微装配机器人智能控制、FAST 靶标三维感知与柔顺拆装、大型舱段自主精密对接、复杂空间曲线焊缝自主焊接等关键技术难题,相关成果应用于国家重大工程并获得用户认可。
作为项目负责人,主持国家科技重大专项课题、国家重点研发计划子课题、国家自然科学基金青年基金、中国博士后科学基金等项目;担任中国人工智能学会智能机器人专委会委员、中国指挥与控制学会无人系统专委会委员,以及国家自然科学基金委系统评议专家。
在机器人与自动化领域发表高水平学术论文 20 余篇,其中以第一/通讯作者发表顶刊顶会论文 15 篇,涵盖 IEEE TII、TIE、TASE、TIM、RAL 等机器人与自动化领域国际权威期刊,PR、ESWA、MIR 等人工智能与模式识别领域期刊,以及 ICCV、CVPR、ICRA、CASE 等国际顶级会议;申请国家发明专利 20 余件(授权 10 余件),登记软件著作权 10 余件,参与制定国家标准 1 项。
Biography
Yunkai Ma is an Associate Professor at the Institute of Automation, Chinese Academy of Sciences (CASIA). His research focuses on robotic 3D perception and precision autonomous operation, aiming to endow robots with high-accuracy perception and intelligent manipulation capabilities for real-world manufacturing. He has proposed a series of methods for multi-scenario high-precision perception and intelligent operation, addressing key technical challenges including intelligent control of micro-assembly robots, 3D perception and compliant assembly/disassembly of FAST telescope targets, autonomous precision docking of large cabin sections, and autonomous welding of complex spatial seams. These technologies have been deployed in national major engineering projects and recognized by end users.
He serves as Principal Investigator of projects funded by the National Science and Technology Major Project, the National Key R&D Program of China, the National Natural Science Foundation of China (NSFC Young Scientists Fund), and the China Postdoctoral Science Foundation. He is a committee member of the Intelligent Robotics Committee of the Chinese Association for Artificial Intelligence (CAAI) and of the Unmanned Systems Committee of the Chinese Institute of Command and Control (CICC), and serves as an expert reviewer for the NSFC.
He has published more than 20 papers in leading robotics, automation, and AI venues — including IEEE TII, TIE, TASE, TIM, and RAL, as well as PR, ESWA, and MIR, and top international conferences such as ICCV, CVPR, ICRA, and CASE — with 15 as first or corresponding author. He has filed 20+ national invention patents (10+ granted), registered 10+ software copyrights, and contributed to one Chinese national standard.
教育与工作经历
Education & Career
研究方向
Research Interests
招生信息
课题组常年招聘实习生(本科生可优先保研),研究方向为机器人精密自主作业与具身智能。欢迎自动化、计算机、机电一体化等相关专业的同学加入!
Join Us
We recruit interns year-round (priority for postgraduate recommendation for undergraduates) in robotic precision autonomous operation and embodied intelligence. Students in automation, computer science, mechatronics, and related majors are welcome!
研究方向
Research Interests
学术报告
Invited & Conference Talks
- 《混合视觉传感器的研制及其在机器人焊接中的应用》,IEEE CASE,2023 Development of a Hybrid Vision Sensor and Its Application in Robotic Welding, IEEE CASE, 2023
- 《用于从侧面拧紧和拧下螺栓的机器人末端执行器》,IEEE ICRA,2023 A Robotic End-Effector for Side Tightening and Loosening of Bolts, IEEE ICRA, 2023
- 《EPRecon:面向单目视频的实时全景三维重建框架》,IEEE ICRA,2025 EPRecon: An Efficient Framework for Real-Time Panoptic 3D Reconstruction from Monocular Video, IEEE ICRA, 2025
- 《LIRA:基于多模态大语言模型的推理重建》,IEEE ICCV,2025 LIRA: Reasoning Reconstruction via Multimodal Large Language Models, IEEE ICCV, 2025
- 《AI 赋能的机器人自主微装配》,第二届聚变能源技术研讨会(大会报告),2026 AI-Empowered Autonomous Robotic Micro-Assembly, 2nd Symposium on Fusion Energy Technology (Keynote), 2026
- 《融合多模态视觉的机器人三维感知与精密自主作业》,第二届信息处理与智能感知高峰论坛,2025 3D Perception and Precision Autonomous Operation of Robots with Multimodal Vision, 2nd Summit Forum on Information Processing and Intelligent Perception, 2025
- 《大模型技术在机器人中的应用及思考》,中关村“火花”活动 · DeepSeek 平权后的大模型应用,2025 Large Model Technology for Robotics: Applications and Reflections, Zhongguancun "Spark" Forum on Post-DeepSeek LLM Applications, 2025
主持项目
Projects as Principal Investigator
参与项目
Projects as Co-Investigator
研究平台
Research Platforms
授权发明专利(部分)
Granted Invention Patents (Selected)
软件著作权(部分)
Software Copyrights (Selected)
国家标准
National Standard
注:共申请国家发明专利 20 余件(授权 10 余件),登记软件著作权 10 余件,以上为部分代表成果。
Note: 20+ national invention patents filed (10+ granted) and 10+ registered software copyrights in total; the above lists selected items.
评审专家
Expert Reviewer
- 国家自然科学基金委系统评议专家Expert Reviewer, National Natural Science Foundation of China (NSFC)
- “十五五”国家重点研发计划重点专项评审专家Review Expert, Key Special Projects of the National Key R&D Program (15th Five-Year Plan)
- 北京信息产业协会专家Expert, Beijing Information Industry Association
- “雄才杯”创新创业大赛决赛评审专家Final-Round Judge, "Xiongcai Cup" Innovation and Entrepreneurship Competition
- 雄安垂直大模型应用大赛决赛评审专家Final-Round Judge, Xiong'an Vertical Large-Model Application Competition
社会兼职
Academic Services
- 中国人工智能学会 智能机器人专业委员会 委员Committee Member, Intelligent Robotics Committee, Chinese Association for Artificial Intelligence (CAAI)
- 中国指挥与控制学会 无人系统专业委员会 委员Committee Member, Unmanned Systems Committee, Chinese Institute of Command and Control (CICC)
- IEEE TMECH、TII、TIM、TIE、RCIM 等国际期刊审稿人Reviewer for IEEE TMECH, TII, TIM, TIE, RCIM, and other international journals
- ICRA、IROS、CVPR 等国际会议审稿人Reviewer for ICRA, IROS, CVPR, and other international conferences
实习生招聘
Intern Recruitment
- 招聘人数:常年招聘实习生 1–2 人 Openings: 1–2 interns, recruited year-round
- 研究内容:机器人精密自主作业、具身智能 Research: Robotic precision autonomous operation and embodied intelligence
- 欢迎专业:自动化、计算机、机电一体化等相关专业 Majors: Automation, computer science, mechatronics, and related fields
- 基本要求:良好的数理基础、编程能力与沟通表达能力 Requirements: Solid mathematical foundation, programming skills, and communication ability
- 我们提供:良好的科研平台与待遇;表现优秀的本科生可优先保研 We offer: An excellent research platform and competitive benefits; outstanding undergraduates receive priority for postgraduate recommendation
联系我们
如果你对以上方向感兴趣,欢迎将简历发送至:
Contact Us
If you are interested, please send your CV to:
中国科学院自动化研究所 · 多模态人工智能系统全国重点实验室 · 北京市海淀区中关村东路95号 Institute of Automation, CAS · State Key Laboratory of Multimodal Artificial Intelligence Systems · No. 95 Zhongguancun East Road, Beijing